

Demand for determining a trusted and
accurate vehicle’s position in real time is driving new digital infrastructures
to correct signals broadcasted by Global Navigation Satellite Systems (GNSS) which
are affected by errors.
As the investments in autonomous driving increasingly
depend on these facilities, the challenge is the realization of systems that
must become economically sustainable, resilient to cyber-attack and compliant with
global standards.
The ION GNSS+ 2026 – the world’s
largest international technical meeting and showcase of GNSS and related
technology – held in Orlando (USA) from September 14th to 18th
was an opportunity to present a new approach to monitor the errors caused by
GNSS signal degradations, as part of a research conducted by Radiolabs in
collaboration with ASI – the Italian Space Agency.
In particular the paper Integrity Monitoring of SSR Services
for a Dual Automotive and Rail augmentation Network – presented by Mauro Cardone of ASI – deals
with the State Space Representation (SSR) methodology to model individual GNSS
error sources to be transmitted separately rather than combined into aggregate
correction messages. This disaggregated approach is peculiar to realize a
flexible, scalable and liability-proof correction service. As is the case for
the RAN – Rete di Augmentation
Nazionale that already complies with the Observation
Space Representation (OSR) approach and the upcoming RTCM SC-134 Messages for high
Integrity precise positioning standard.
The modelling of SSR service – able to
supply an unlimited number of users at the same time – makes it ideally suited
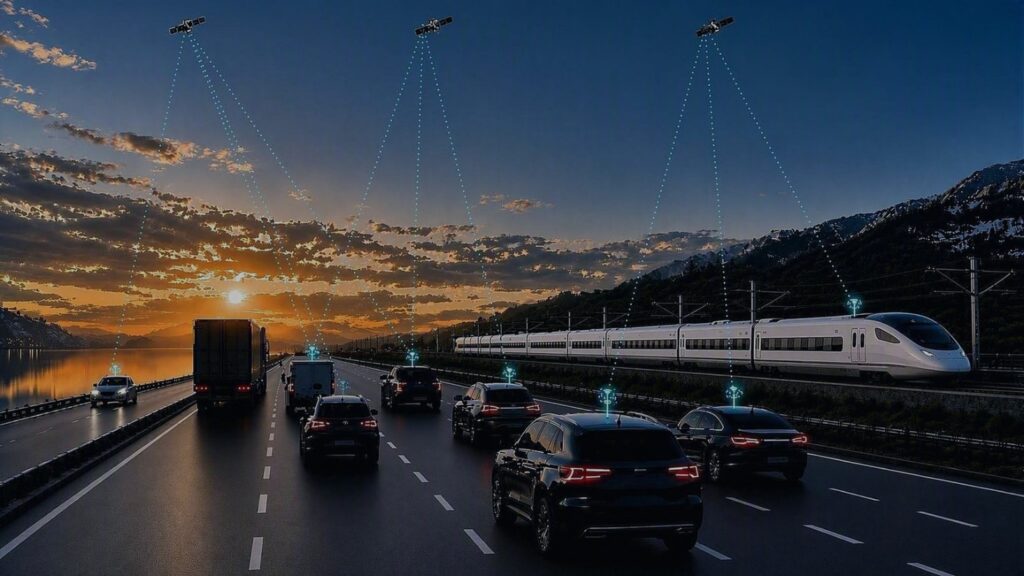
for autonomous cars, trains, ship-berthing and drones. Therefore, SSR is at the
heart of the RAN, the multi-tier augmentation network actually developed in
Italy for train and car applications within a contract awarded by ASI to a
consortium including Leonardo, Sogei, RFI and Radiolabs. RAN builds on the
information provided by EGNOS and the Galileo High Accuracy
Service (HAS) and adds as its main contribution the incremental
information generated by a second-tier network federating either a dedicated or
a qualified third-party network.
This multi-level architecture – designed by
Radiolabs and tested in projects with ESA and EUSPA – is based on
a new paradigm built around a system of interconnected and independent systems.
The benefits are lower costs and time of realization respect to a dedicated
infrastructure, as well as a greater resilience to cyberattacks, since the
solution doesn’t rely on a single system or GNSS constellation. By reusing much
of the EGNOS and Galileo infrastructure, the local network becomes an
additional component, with reference stations placed along rail and road
routes, also to taking advantage of existing infrastructure where to install.
The SSR-based methodology is designed to model
the satellite position corrections to satisfying the requirements of the ERTMS
and CCAM systems for determining respectively the train and car GNSS-based
trusted position with the prescribed liability in terms of safety. The entire
process, based of SSR state components under watch, combined with a 3-stage FDE
– Fault Detection and Exclusion with barriers to block faulty data and a novel MHSS–
Multiple-Hypothesis Solution Separation (MHSS) is optimised to ensure that a
fault impacting on the estimated safe vehicle’s position is identified almost
immediately.
An important innovation brought by our
research is the way to assess the level of trustiness in determining the
vehicle’s position applied to carrier phase corrections RTK / NRTK,
PPP and PPP-RTK. A unified
commitment is elaborated to overcome the today’s limitation of a separate trust
for each service. With these data a generic GNSS receiver on board the vehicle is
able to estimate the position and velocity bounded by the protection level.
Looking
ahead, the next step would be to generalize the multi-tier architecture of the RAN
by adding additional layers to enhance GNSS positioning capabilities for new
transport applications. One layer would be useful to take advantage of the
numerous GNSS receivers already present on roadside units (RSUs) of ‘Smart
Road’ infrastructure. This would create a more widespread local network to
serve both rail and road users, since roads and railways are generally close to
each other. Another layer could be dedicated to managing the new LEO-PNT
constellations and 5G technology, with the goal of merging with
different technologies to help develop autonomous driving systems.
Mauro
Cardone, concluding his speech has underlined the importance of the test
campaign of the RAN planned for next October near Bologna – the first test in
Europe to validate the augmentations services for both the rail and automotive
applications. He also mentioned the future evolution of RAN for extending the
services to drones and autonomous ship berthing applications.
